Repo

SuperMimic-Reproduced

Reproduces SuperMimic end to end for G1 motion tracking, including data prep, differentiable world-model training, BPTT policy learning, and Appendix F eval.

GitHub ↗Oct 21, 2026Paper ↗

  • rl
  • humanoid-control
  • world-model
  • mujoco-warp
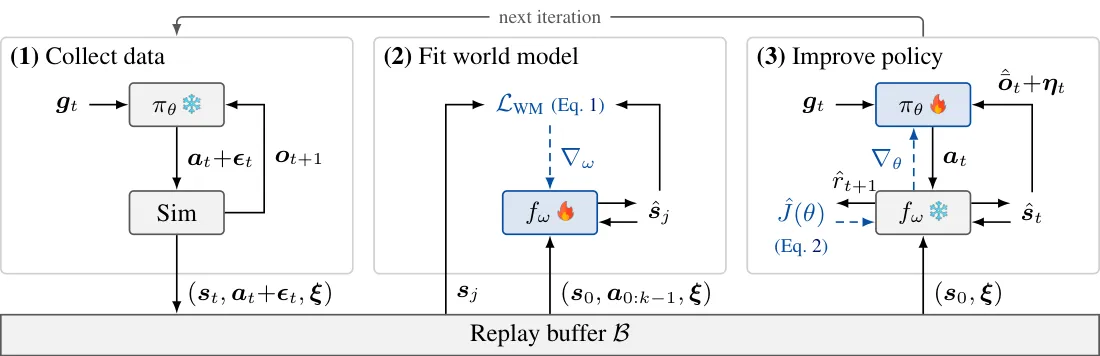
Three-stage pipeline diagram showing data collection, world model fitting, policy improvement

What it is

From-scratch SuperMimic reproduction for humanoid motion tracking with a differentiable world model and BPTT policy training on mjlab/MuJoCo Warp. Train and evaluate Unitree G1 motion-tracking policies with a reproduced SuperMimic pipeline: data conversion, differentiable FK, learned world model, BPTT actor-critic, benchmarking, and replay.

Key results

  • Hits 0.824 LAFAN1 score in 1.66 h on 1× RTX 5090
  • World-model 8-step open-loop error is 0.0065-0.0099
  • Runs ~2×10^5 env-steps/s at 4096 envs; 4-GPU efficiency is 91%

Shows SuperMimic-style differentiable world-model control can be reproduced at paper scale on commodity RTX 5090 hardware.

One useful ML email a week.

Worth your time, not all of your time.

We track new ML work across papers, code, and data, then keep only the pieces worth a closer look. Selected, not collected.

Papers.Data.Code

The Weekly ML Signal

Selected, not collected.

One useful ML email a week: the papers, repos and datasets worth your attention.

Worth your time, not all of your time.