
What it is
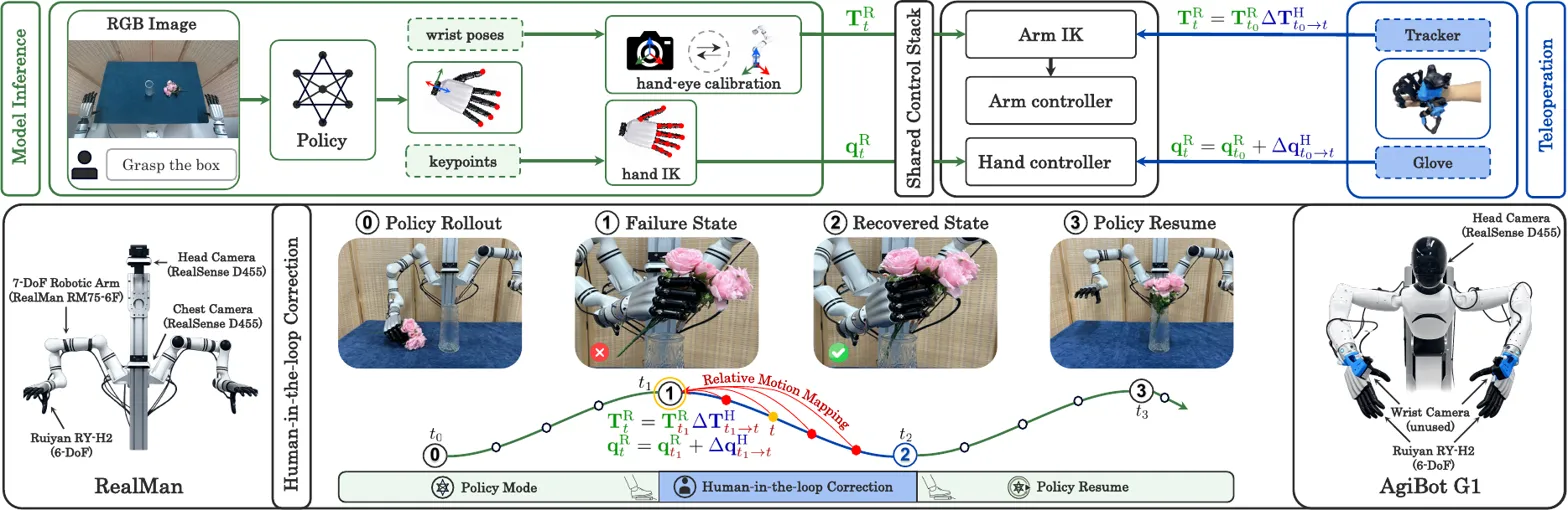
Large real-robot dataset for egocentric bimanual teleoperation: 54k episodes across 193 dexterous tasks with RGB-D, proprioception, actions, and language. 54,454 real-robot teleop episodes across 193 tabletop manipulation tasks, with dual egocentric RGB-D streams, 74D state/action time series, and 1-12 English instructions per episode.
Key results
- 54,454 episodes, 20,750,677 frames at 30 Hz
- 193 tasks across 7 manipulation categories
- 2 RGB-D cameras, 74D state/action, Apache-2.0
Useful for training and benchmarking language-conditioned visuomotor policies for real-world bimanual dexterous manipulation.