
What it is
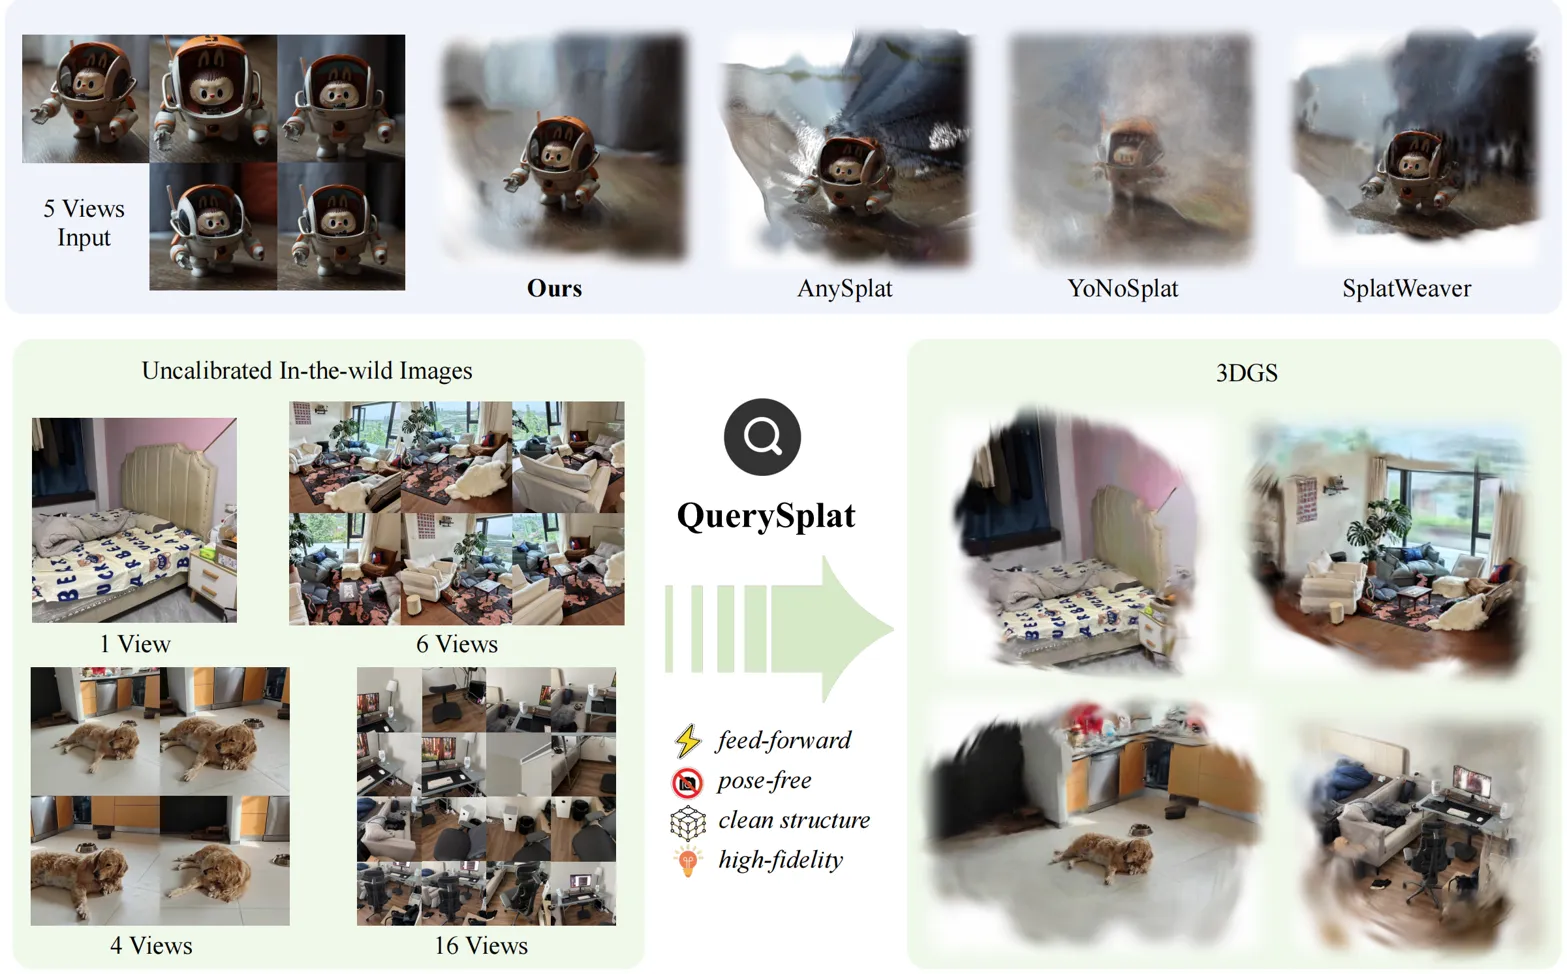
Predicts and renders 3D Gaussian scenes from a folder of images, with optional test-time optimization and camera/depth export via VGGT-Omega. Turn a set of scene images into a rendered 3D Gaussian representation, predicted cameras, and depth outputs, with optional test-time optimization and PLY/point-cloud export.
Key results
- Supports feed-forward inference or TTO with 20 steps by default
- Exports Gaussian PLYs at multiple opacity thresholds; default 0.05
- Requires separate QuerySplat and VGGT-Omega checkpoints for inference
Shows that 3DGS prediction can be packaged as a single inference pipeline with decoupled scene prediction plus optional per-scene refinement.