
What it is
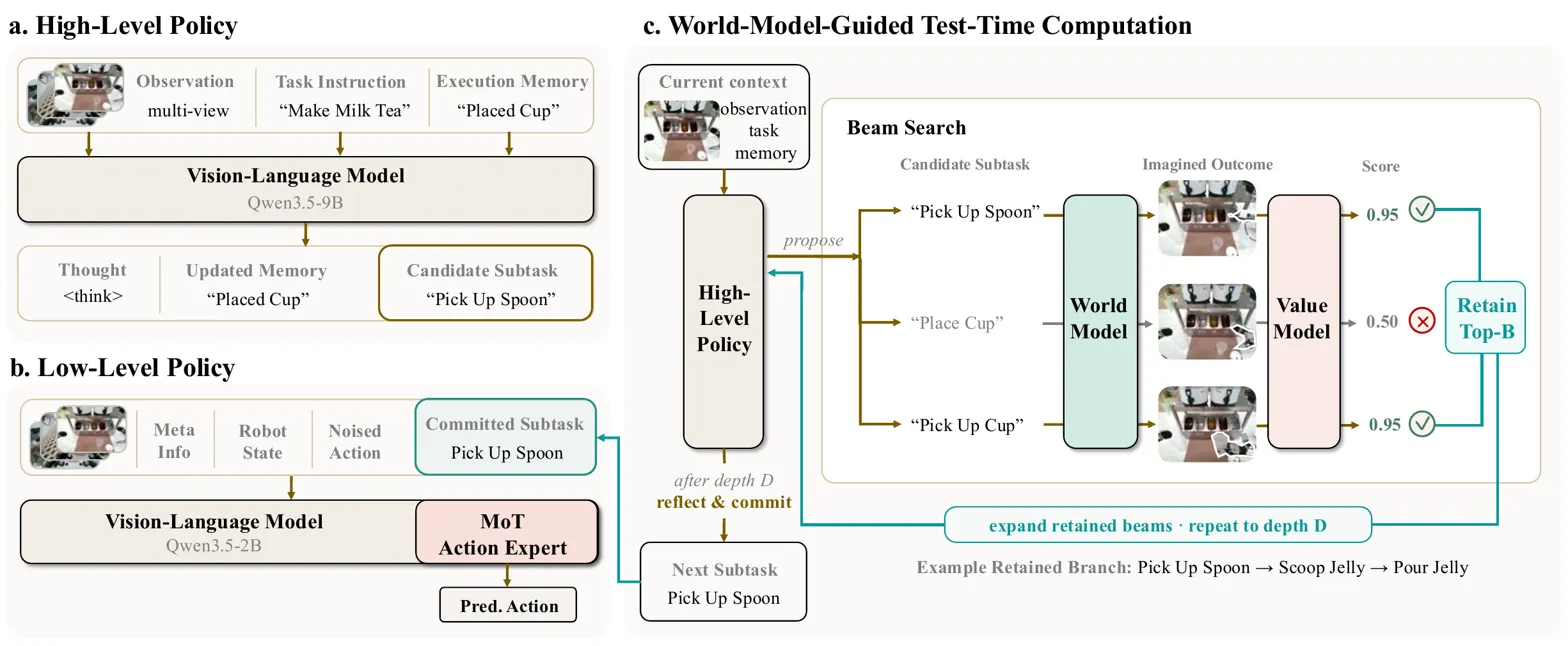
Hierarchical vision-language-action model for long-horizon robot manipulation with world-model-guided test-time subtask search and cross-embodiment low-level control. Plans long-horizon manipulation as subtasks, searches alternatives at test time when needed, and executes the chosen subtask with a generalist low-level policy across robot embodiments.
Key results
- Uses world-model-guided test-time computation for subtask search
- Trained on 40,115 hours of heterogeneous real-world robot data
- Supports cross-embodiment control via a unified 40D state/action space
Shows that hierarchical test-time reasoning can be integrated into a generalist robot foundation model for long-horizon manipulation.