Dataset

HiFi-UMI-2K

Contains 2,000 hours of synchronized 6-view bimanual manipulation episodes with 20D state/action trajectories, gripper signals, task text, and metadata.

Hugging Face ↗Jul 19, 2026

  • robotics
  • bimanual-manipulation
  • imitation-learning
  • multiview-video
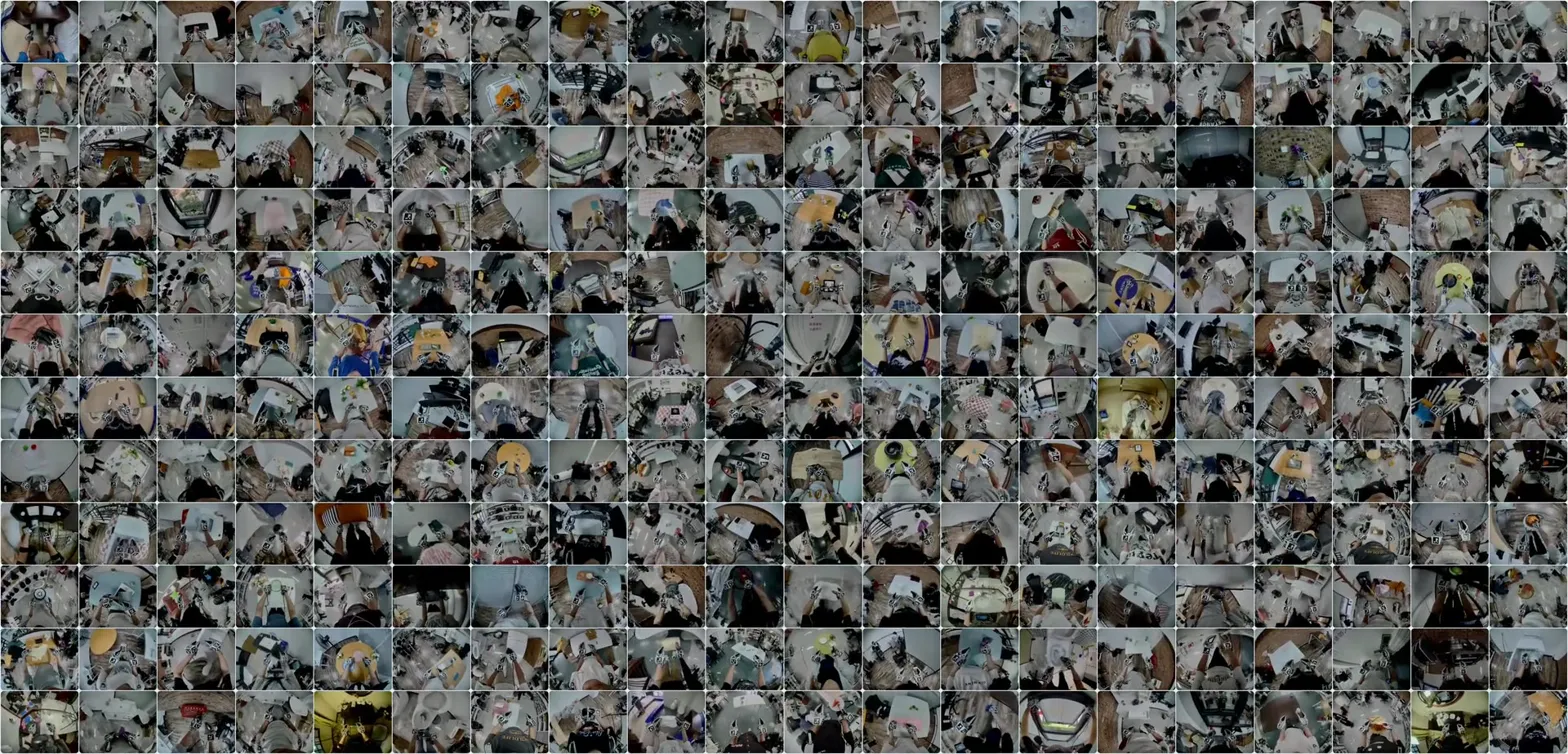
Large grid of dataset samples showing egocentric/robot manipulation scenes, illustrates dataset contents

What it is

2,000 hours of high-fidelity robot-free bimanual manipulation data with synchronized 6-view video, trajectories, gripper states, and language. 2,000 hours of robot-free bimanual demos with 6 synchronized camera views, calibrated 20D state/action trajectories, gripper states, task text, and QC metadata across 480+ scenes.

Key results

  • 2,000 released hours from a 20,000+ hour corpus
  • 6 synchronized camera views per episode
  • CC BY 4.0; Parquet tables + MP4 videos

Useful for pretraining and post-training robot manipulation policies from human demonstrations without robot teleoperation.

One useful ML email a week.

Worth your time, not all of your time.

We track new ML work across papers, code, and data, then keep only the pieces worth a closer look. Selected, not collected.

Papers.Data.Code

The Weekly ML Signal

Selected, not collected.

One useful ML email a week: the papers, repos and datasets worth your attention.

Worth your time, not all of your time.