Dataset

EmbRACE

Contains 3,421 egocentric human demonstrations in 55 environments and a 686-task benchmark in 7 more, for closed-loop embodied navigation/manipulation.

Hugging Face ↗Sep 28, 2026Paper ↗Code ↗

  • multimodal
  • egocentric
  • vision-language-navigation
  • simulation
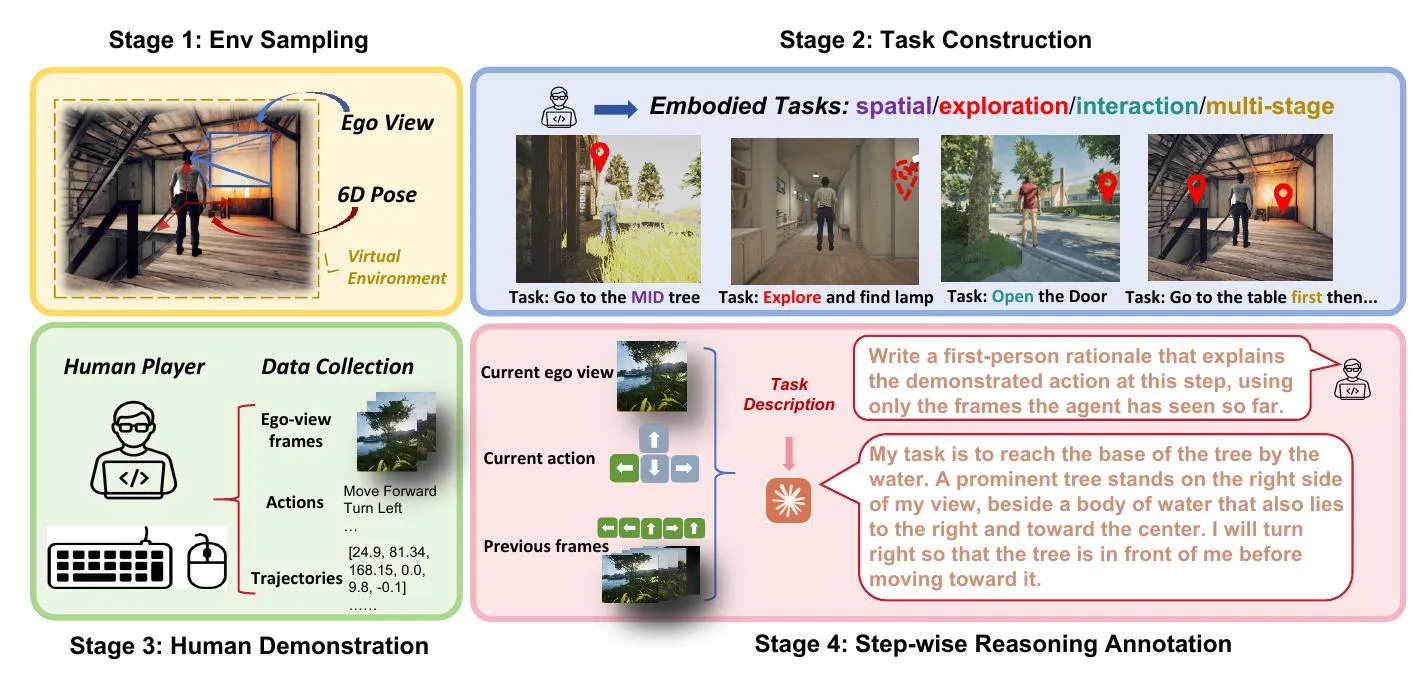
Four-stage pipeline diagram showing data collection and annotation process for embodied tasks

What it is

Egocentric embodied reasoning dataset with step-level human rationales plus a closed-loop benchmark across unseen simulated environments. 3,421 human demos over 55 UE environments plus a 686-task benchmark in 7 unseen environments; 48,264 egocentric steps with verified first-person rationales, actions, poses, and door/object state trajectories.

Key results

  • 3,421 dataset tasks + 686 benchmark tasks
  • 48,264 rationale-labeled steps; 10,552 benchmark steps
  • 62 UE environments total; frames are 640x480; CC-BY-NC-4.0

Useful for training and evaluating embodied agents that must act from egocentric vision and language in closed loop.

One useful ML email a week.

Worth your time, not all of your time.

We track new ML work across papers, code, and data, then keep only the pieces worth a closer look. Selected, not collected.

Papers.Data.Code

The Weekly ML Signal

Selected, not collected.

One useful ML email a week: the papers, repos and datasets worth your attention.

Worth your time, not all of your time.