Repo

INTACT-JEPA

Learns a direct goal-conditioned controller inside a JEPA world model by mapping both local motion change and future goal intent to the same action law.

GitHub ↗Jul 28, 2026Paper ↗

  • robotics
  • world-models
  • goal-conditioned-control
  • jepa
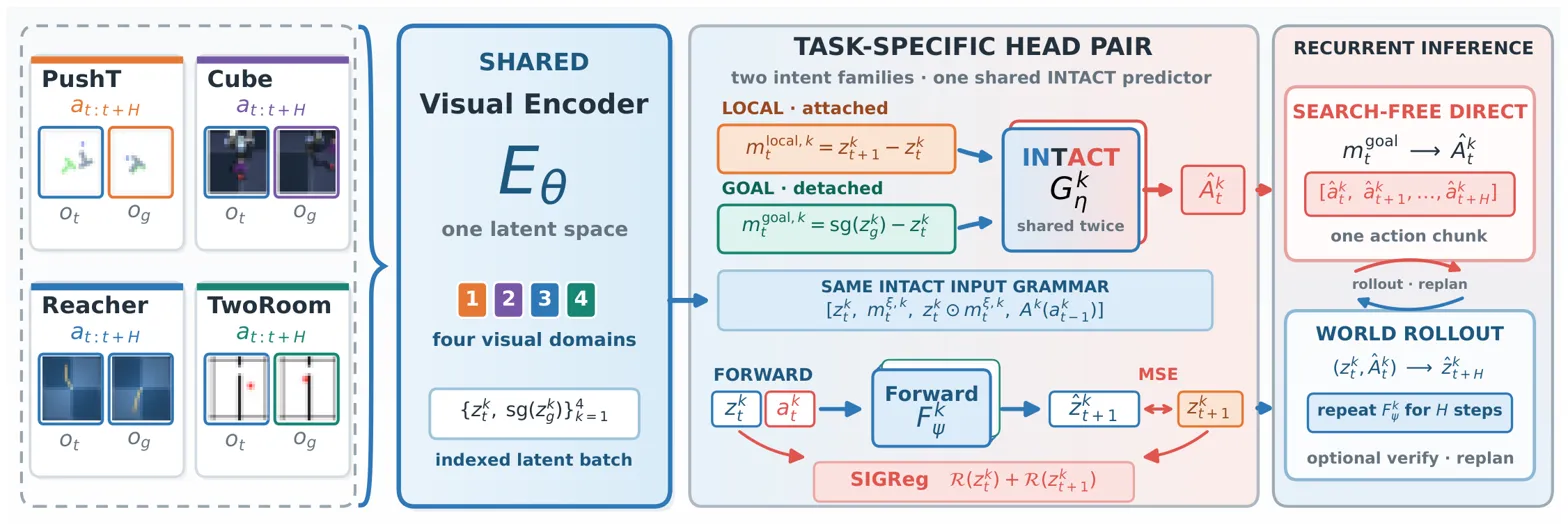
Detailed pipeline diagram showing shared encoder, task-specific heads, and recurrent inference

What it is

Goal-conditioned JEPA world model that learns direct intent-to-action control, avoiding broad action search at deployment. Predicts actions directly from current state and goal intent in a JEPA world model, training one shared intent-to-action operator on both observed local changes and deployable goals so control can run without CEM/MPPI search.

Key results

  • 95.33% direct macro SR in 1 epoch with 0 search
  • 2.9-5.5 ms direct-control latency; 23.44x fewer candidates
  • Shared encoder: 89.39% direct SR vs 66.17% for LeWM CEM 300x30

Shows world models can answer the inverse control query directly, without broad action search at deployment.

One useful ML email a week.

Worth your time, not all of your time.

We track new ML work across papers, code, and data, then keep only the pieces worth a closer look. Selected, not collected.

Papers.Data.Code

The Weekly ML Signal

Selected, not collected.

One useful ML email a week: the papers, repos and datasets worth your attention.

Worth your time, not all of your time.