Dataset

TouchScale

Contains 100 hours of egocentric human manipulation with synchronized RGB-D, dual wrist video, and full-hand tactile signals for visuo-tactile learning.

Hugging Face ↗Sep 30, 2026Paper ↗

  • robotics
  • visuo-tactile
  • egocentric
  • tactile
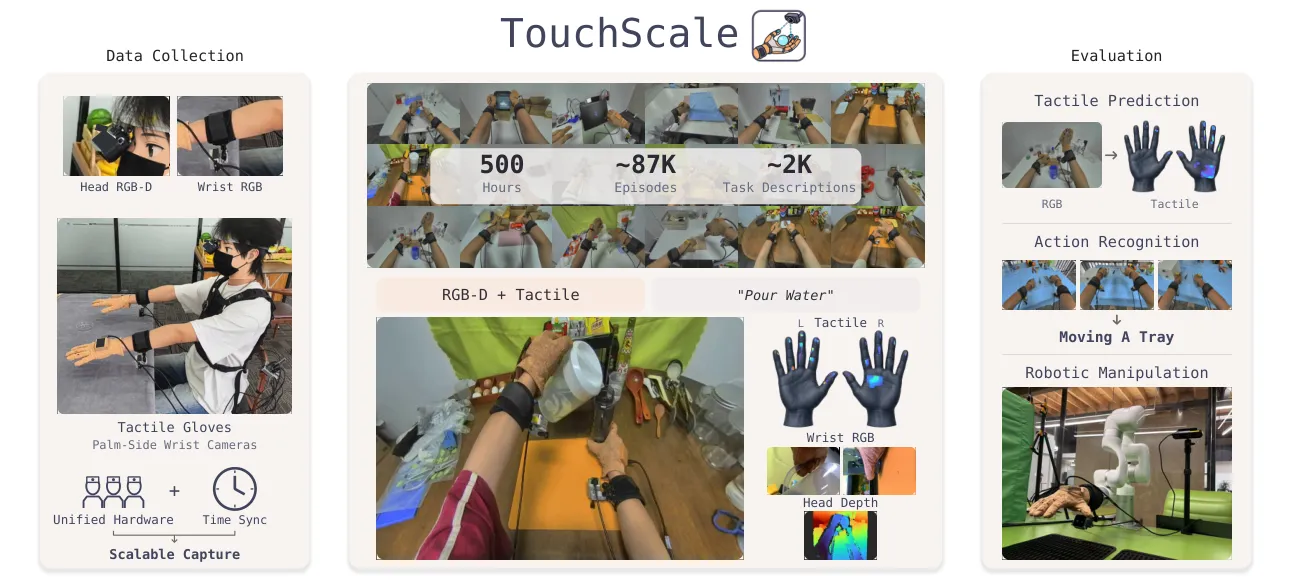
Overview figure showing data collection, dataset scale, and evaluation tasks of TouchScale

What it is

Large egocentric visuo-tactile manipulation dataset with synchronized RGB-D, wrist video, and dense tactile glove signals from human demonstrations. 100 released hours of egocentric human manipulation data, scaling to 500 hours, with a unified rig: head RGB-D, two wrist cameras, and full-hand tactile gloves with 880 taxels.

Key results

  • 100 hours released; 500 hours planned
  • 1 head-mounted RGB-D camera + 2 wrist cameras
  • Full-hand tactile gloves with 880 taxels

Useful for training and evaluating visual-tactile models for everyday manipulation from human demonstrations.

One useful ML email a week.

Worth your time, not all of your time.

We track new ML work across papers, code, and data, then keep only the pieces worth a closer look. Selected, not collected.

Papers.Data.Code

The Weekly ML Signal

Selected, not collected.

One useful ML email a week: the papers, repos and datasets worth your attention.

Worth your time, not all of your time.